ReVolt is my mobile-robot platform for bringing mechanical design, embedded electronics and robot software into one working system. It serves as a practical environment for learning and experimentation across sensing, mapping, navigation and control.
Design & development
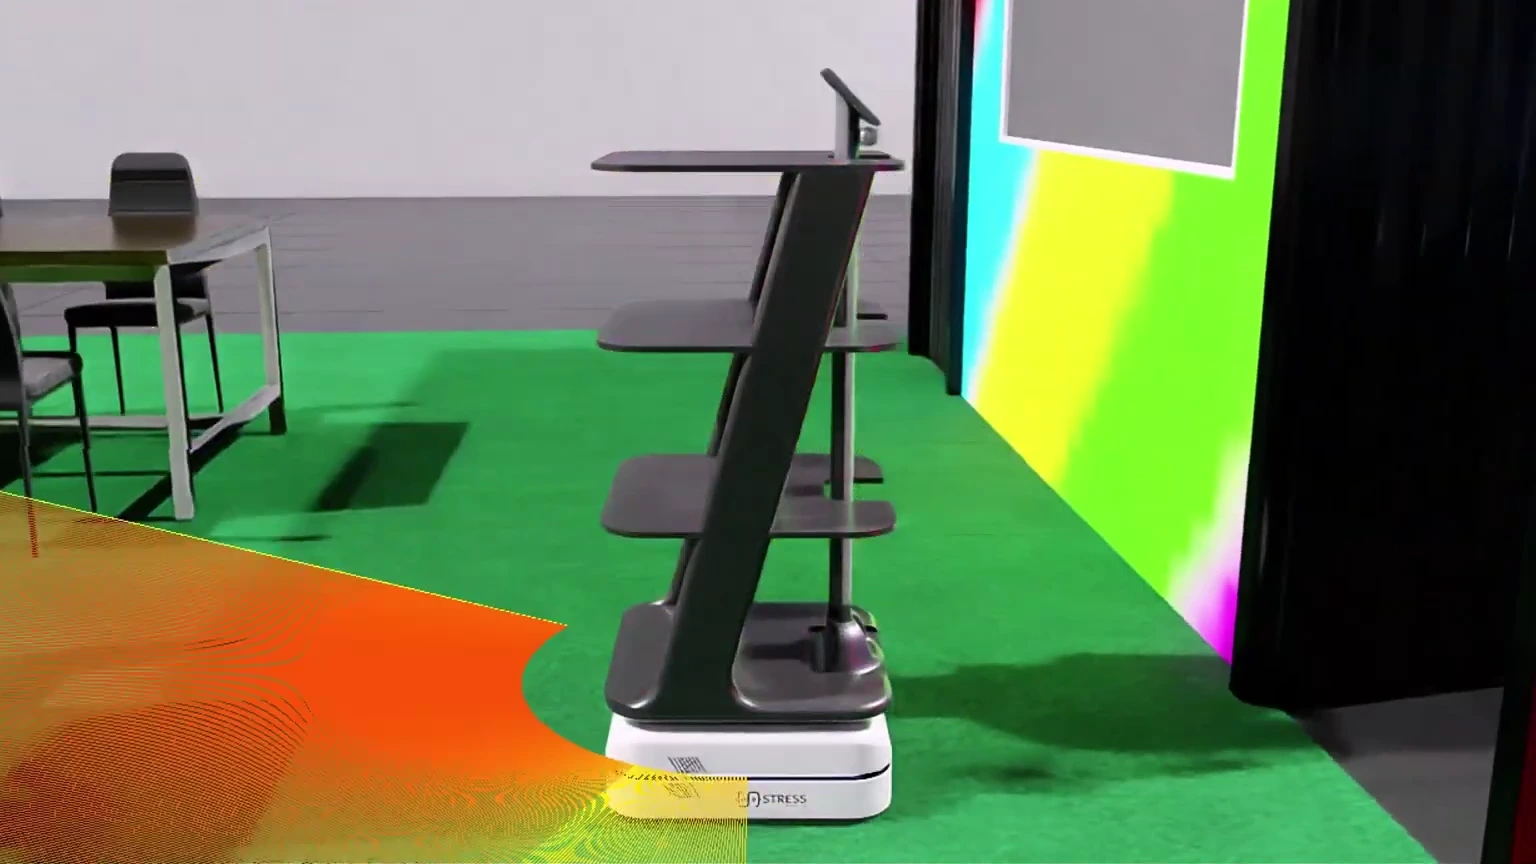
I designed the robot in Onshape, fabricated its chassis and integrated LiDAR and camera sensing with Raspberry Pi and Arduino hardware. I used ROS 2, Gazebo and RViz to test navigation and explore teleoperation, with both physical and simulated versions of the platform.
Development approach
I worked across the physical platform and its software representation: designing the chassis in Onshape, fabricating the structure and integrating the computing and sensing hardware. Raspberry Pi and Arduino formed part of the hardware setup, alongside LiDAR and camera sensing.
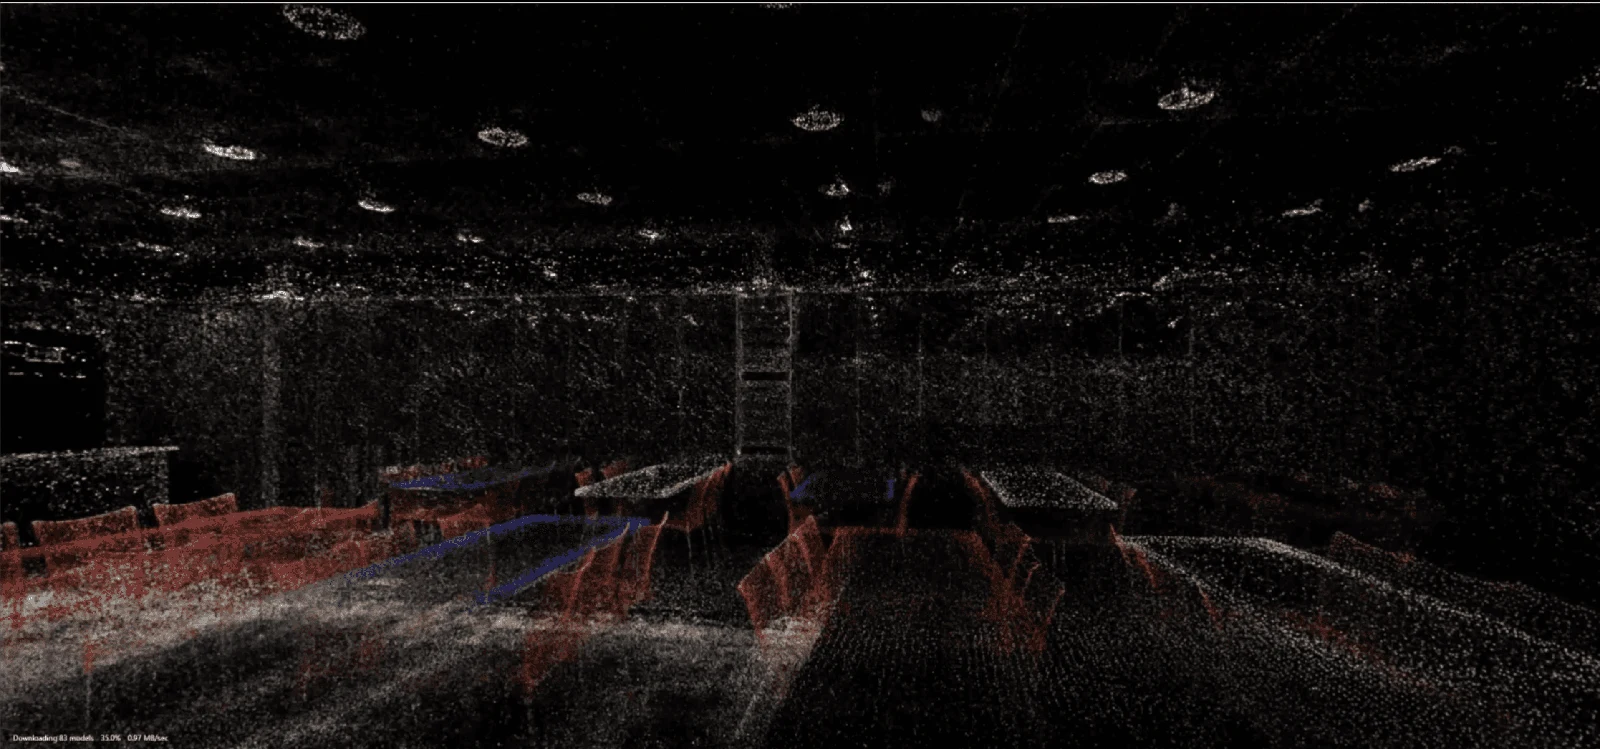
ROS 2 connects the software side of the platform, with Gazebo and RViz supporting simulation and visual inspection. Having physical and simulated versions makes it possible to investigate robot behaviour from more than one angle, from the mechanical assembly to the data and commands used by the software.
Outcome
ReVolt resulted in a physical prototype with supporting software and simulation work for navigation, mapping and teleoperation experiments. The public repository and demonstration document the platform and its hardware integration.