This case study brings together two distinct UAV development tracks: an agricultural bird-deterrence drone at Innov8 Hub and separate low-cost flight-control research. Both involved physical construction and flight testing, with different technical aims and project contexts.
Hardware development
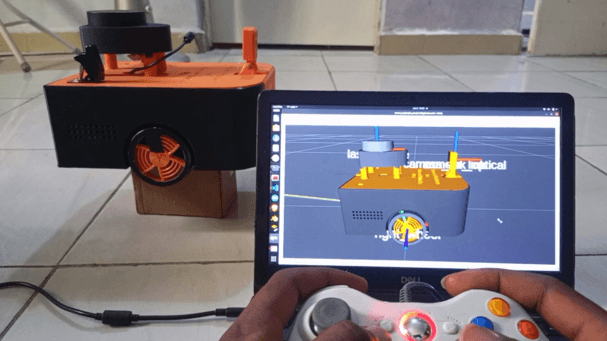
For the agricultural project, I contributed to design, fabrication and flight-control work and integrated an ArduPilot-controlled siren payload. In separate low-cost UAV R&D, I led Arduino/IMU integration, complementary filtering and PID tuning, documenting flight-test iterations to improve hover stability and reduce vibration.
Development approach
The agricultural work combined airframe development with an application payload. I contributed to design, fabrication and flight-control work and integrated a siren controlled through ArduPilot, connecting the drone platform to the bird-deterrence task.
The separate low-cost research focused on Arduino and IMU integration, complementary filtering and PID tuning. I documented flight-test iterations while working on hover stability and vibration. Keeping these tracks separate makes the role of application integration in one, and flight-control experimentation in the other, clear.
Outcome
The projects produced hardware prototypes and recorded flight-test learning across agricultural payload integration and low-cost flight-control development. Together, the work spans physical fabrication, embedded integration and flight-test iteration.